Sunday, April 22, 2012

Dummy Pre-Alpha


Few weeks ago I started working on a robotic hand, it's still in pre-alpha phase, because of the claws that are not yet operational, but I wanted to show you my progress.


Well, you may wonder why to call it Dummy ? Its name comes from the Iron Man movie, where Tony Stark has a robotic helper but it's not working well so it completely fits to my arm. I'm still working on a way how to send data from controller (which I would like to implement to a glove) to hand itself. I wrote some code for sending data in a packet form, because I would like to make the whole arm wireless. Problem is that I have to send positions of all 4 servos (now it sends just position for two of them). This project is definitely more complex than I've expected, so it's going to take me more time to finish it, and that's the reason why there will be more smaller updates.


Monday, April 16, 2012

AR.Drone

Hi there. First of all, I would like to apologize for almost 2 months of inactivity. I had lot of other things, but I was working on a new project. Unfortunately it's not finished yet.
 

Awesome thing is that I get an AR.Drone for my birthday, to be honest quadrocopter had been in my mind for quiet some time. I'm really excited about working/playing with it. I also found a processing and arduino libraries for it. I'm considering to buy a wi-fi xbee radio to control this drone with arduino. And about that project I mentioned above, I hope that it will be finished soon.

Monday, February 27, 2012

Observer 1.4 [update]

Hi there. I am presenting you version 1.4. 


The mayor change is that I’ve added third wheel to the back. I’m still experimenting with that but as you can see in the video observer can now drive over various obstacles without any problems. Also I moved Bluetooth module under the PCB to use the space that was there. Right now I’m drawing new PCB for observer, so that means next update will be version 2.0. I don’t want to spoil it, so I just say there’s going to be multiple sensors and when all will work out well I believe that version 2.0 will be awesome.


Sunday, February 12, 2012

Observer 1.3 [update]

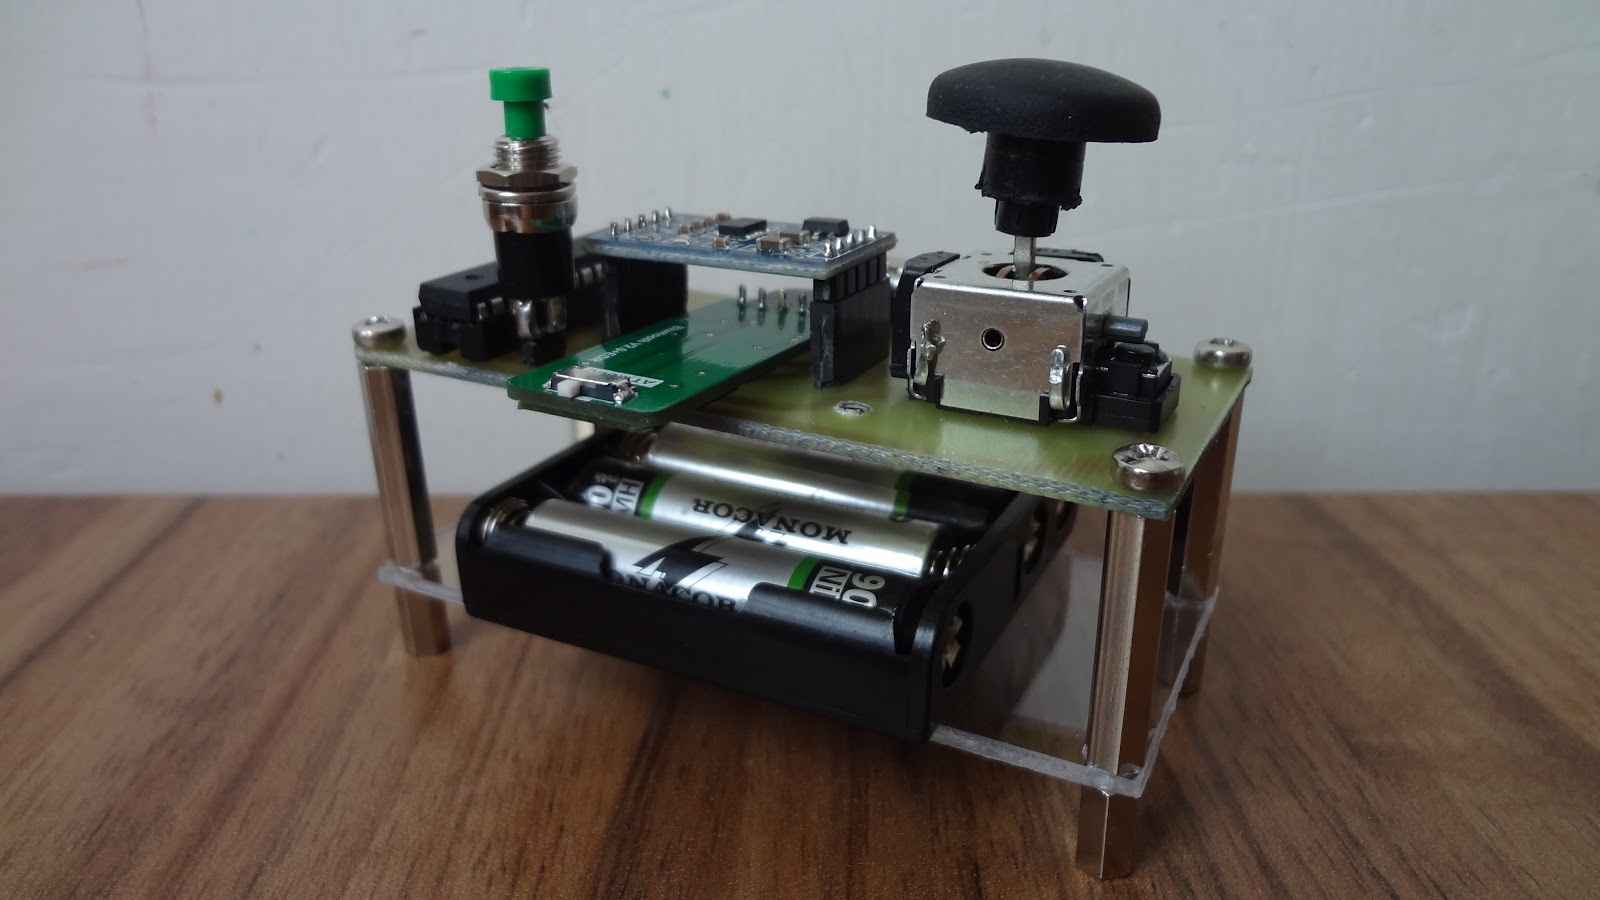
Bluetooth module has arrived, so I want to show you pics of another update. 


Reason that version 1.2 is missing is that this version (controller) was build on breadboard. At first I thought that I would put controller in some case, but then I decided to leave it like this. So what’s new? I’ve added analog stick that I’ve desoldered from old gamepad. But there’s still option to control robot via accelerometer. For that purpose I’ve used pushbutton that is part of analog stick. There’s still one breaked-out analog pin on Observer waiting for some sensor. I’ve been trying to add there LM335, but I’m dealing with analog reference issue. I found out that AAA batteries aren’t very good for such robot and that having separate power sources for servos and for microprocessor would be much better.


Sunday, January 29, 2012

Observer 1.1 [update]

It took me more time then I've expected, but here's and update.


I have used second Arduino (Duemilanove) as an controller. For now robot is being controlled via laptop, but I have already ordered second bluetooth module for standalone controller. I thought adding LED's as front lights would be cool also.

Sunday, December 11, 2011

Observer Alpha

So I was finally able to build my first driving robot.  


It's still an Alpha version so it has no special functions but in future I would like add more sensors and maybe even a digital camera that will record what's going on around. Since this is just first release I won't put here any code or tutorial but I will be updating this post. 

Monday, November 21, 2011

Servo etcher

Since I like to fabricate my own PCB’s, it’s obvious that I etch a lot. For that purpose I’m using old CD container.


Thing that I hate is that the whole process is slow and ineffective. Thus I’ve decided to use one of the servo’s that was lying around. I’ve hot glued servo to the plastic cover of CD container. All I needed then was to program an Arduino, so it could change speed of servo with a values that comes of a potentiomer.
(Code I'm using is "Knob" from Arduino IDE Servo library)